CJ3M-CPU3[] / -CPU1[] / CJ2M-MD21[]
CJ-series CJ3M CPU Units, Pulse I/O Modules
CJ Series continues. And evolves. Ideal for basic equipment upgrades and expansion
Related Contents
 Application Solutions
- Features
- Lineup
- Specifications
- Dimensions
- Catalog / Manual / CAD / Software
last update: October 1, 2026
General Specifications
| Item | CJ3M-CPU1[]/3[] | |
|---|---|---|
| Enclosure | Mounted in a panel | |
| Grounding | Less than 100 Ω | |
| CPU Unit Dimensions | CJ3M-CPU1[]
90 mm × 75 mm × 31 mm (H × D × W) CJ3M-CPU3[] 90 mm × 75 mm × 62 mm (H × D × W) |
|
| Weight *1 | CJ3M-CPU1[]: 140 g or less
CJ3M-CPU3[]: 240 g or less |
|
| Current Consumption | CJ3M-CPU1[]: 5 VDC 0.26 A, 24 VDC 0.003 A
CJ3M-CPU3[]: 5 VDC 0.91 A, 24 VDC 0.003 A |
|
| Use
Environment |
Ambient Operating Temperature | 0 to 55°C |
| Ambient Operating Humidity | 10% to 90% (with no condensation) | |
| Atmosphere | Must be free from corrosive gases. | |
| Ambient Storage Temperature | -20 to 70°C | |
| Altitude | 2,000 m or less | |
| Pollution Degree | 2 or less: Conforms to IEC 61010-2-201. | |
| Noise Immunity | 2 kV on power supply line (Conforms to IEC 61000-4-4.) | |
| Overvoltage Category | Category II: Conforms to IEC 61010-2-201. | |
| EMC Immunity Level | Zone B | |
| Vibration Resistance | Conforms to IEC60068-2-6.
5 to 8.4 Hz with 3.5-mm amplitude, 8.4 to 150 Hz Acceleration of 10 m/s2 for 100 min in X, Y, and Z directions (10 sweeps of 10 min each = 100 min total) |
|
| Shock Resistance | Conforms to IEC60068-2-27.
150 m/s2, 3 times in X, Y, and Z directions (100 m/s2 for Relay Output Units) |
|
| Battery | Life | 5 years at 25°C |
| Weight | Approx. 10 g | |
| Model | CJ1W-BAT01 (Sold separately) | |
| Applicable Standards | EU, cULus, RCM, KC *2 | |
*1. Includes the weights of the End Cover.
*2. Refer to the OMRON website (http://www.ia.omron.com/) or consult your OMRON representative for the most recent applicable standards for each model.
Performance Specifications
| Items | CJ3M-CPU[][] | ||||
|---|---|---|---|---|---|
| User Memory | CPU11/31: 5K steps
CPU12/32: 10K steps CPU13/33: 20K steps CPU14/34: 50K steps CPU15/35: 100K steps |
||||
| I/O Bits | 5,120 bits | ||||
| Processing
Speed |
Overhead Processing Time *1 | Normal Mode:CPU3[]: 260 μs
CPU1[]: 160 μs |
|||
| Execution Time | Basic Instructions: 0.04 μs min.;
Special Instructions: 0.06 μs min. |
||||
| Interrupts | I/O Interrupts and External Interrupts | Interrupt task startup time: 31 μs
Return times to cyclic tasks: 10 μs |
|||
| Scheduled Interrupts | Minimum time interval: 0.4 ms (set in 0.1 ms increments) | ||||
| Interrupt task startup time: 30 μs
Return time to cyclic task: 11 μs |
|||||
| Maximum Number of Connectable Units | Total per CPU Rack or Expansion Rack: 10 Units max.;
Total per PLC: 80 Units max. |
||||
| Basic I/O Units | 80 Units max.
However, a maximum of two CJ1W-INT01 Interrupt Input Units can be mounted. |
||||
| Special I/O Units | Units for up to 96 unit numbers can be mounted.
(Unit numbers run from 0 to 95. Units are allocated between 1 and 8 unit numbers.) |
||||
| CPU Bus Units | CPU1[]: 16 Units max.
CPU3[]: 15 Units max. |
||||
| Pulse I/O Modules | 2 max. | ||||
| Slots for which interrupts
can be used |
Slots 0 to 4 on CPU Rack | ||||
| Maximum Number of Expansion Racks | 7 max. | ||||
| CIO Area | I/O Area | 5,120 bits (320 words): Words CIO 0000 to CIO 0319 | |||
| Link Area | 3,200 bits (200 words): Words CIO 1000 to CIO 1199 | ||||
| CPU Bus Unit Area | 6,400 bits (400 words): Words CIO 1500 to CIO 1899 | ||||
| Special I/O Unit Area | 15,360 bits (960 words): Words CIO 2000 to CIO 2959 | ||||
| Pulse I/O Area | 20 inputs, 12 outputs (CIO 2960 to CIO 2963) | ||||
| Serial PLC Link Area | 1,440 bits (90 words): Words CIO 3100 to CIO 3189 | ||||
| EtherCAT Remote Area | 2,368 bits (148 words), 3,800 to 3863 words, 3,900 to
3,963 words, 3,980 to 3,999 words |
||||
| DeviceNet Area | 9,600 bits (600 words): Words CIO 3200 to CIO 3799 | ||||
| Work Area | Internal I/O Area | 3,200 bits (200 words):
Words CIO 1300 to CIO 1499 (Cannot be used for external I/O.) 37,504 bits (2,344 words): Words CIO 4000 to CIO 6143 (Cannot be used for external I/O.) |
|||
| Work Area | 8,192 bits (512 words): Words W000 to W511
(Cannot be used for external I/O.) |
||||
| Holding Area | 8,192 bits (512 words): Words H000 to H511
Bits in this area maintain their ON/OFF status when PLC is turned OFF or operating mode is changed. Words H512 to H1535: These words can be used only for function blocks. They can be used only for function block instances (i.e., they are allocated only for internal variables in function blocks). |
||||
| Auxiliary Area | Read-only: 31,744 bits (1,984 words)
• 7,168 bits (448 words): Words A0 to A447 • 24,576 bits (1,536 words): Words A10000 to A11535 *2 Read/write: 16,384 bits (1,024 words) in words A448 to A1471 *2 |
||||
| Temporary Area | 16 bits: TR0 to TR15 | ||||
| Timer Area | 4,096 timer numbers (T0000 to T4095) | ||||
| Counter Area | 4,096 counter numbers (C0000 to C4095) | ||||
| DM Area | 32k words *3
• DM Area words for Special I/O Units: D20000 to D29599 (100 words × 96 Units) • DM Area words for CPU Bus Units: D30000 to D31599 (100 words × 16 Units) |
||||
| EM Area | 32k words/bank × 1 to 10 banks max.: E00_00000 to
E09_32767 max. *4 |
||||
| CPU[]1/[]2/[]3: 1 bank
CPU[]4/[]5: 10 banks |
|||||
| Index Registers | IR0 to IR15
These are special registers for storing PLC memory addresses for indirect addressing. (Index Registers can be set so that they are unique in each task or so that they are shared by all tasks.) |
||||
| Cyclic Task Flag Area | 128 flags | ||||
| Memory Card | HMC-SD29[]: 2 GB
HMC-SD49[]: 4 GB HMC-SD1A[]: 16 GB |
||||
| Operating Modes | PROGRAM Mode: Programs are not executed.
Preparations can be executed prior to program execution in this mode. MONITOR Mode: Programs are executed, and some operations, such as online editing, and changes to present values in I/O memory, are enabled in this mode. RUN Mode: Programs are executed. This is the normal operating mode. |
||||
| Execution Mode | Normal Mode | ||||
| Programming Languages | Ladder Logic (LD)
Sequential Function Charts (SFC) Structured Text (ST) Instruction Lists (IL) |
||||
| Function
Blocks |
Maximum number of definitions | 2,048 | |||
| Maximum number of instances | 2,048 | ||||
| FB Program Area | 40K steps | ||||
| Tasks | Type of Tasks | Cyclic tasks
Interrupt tasks (Power OFF interrupt tasks, scheduled interrupt tasks, I/O interrupt tasks, external interrupt tasks, and input interrupt tasks (Pulse I/O Module) *3) |
|||
| Number of Tasks | Cyclic tasks: 128
Interrupt tasks: 256 (Interrupt tasks can be defined as cyclic tasks to create extra cyclic tasks. Therefore, the total number of cyclic tasks is actually 384 max.) |
||||
| Symbols
(Variables) |
Type of Symbols | Local symbols: Can be used only within a single task
in the PLC. Global symbols: Can be used in all tasks in the PLC. Network symbols (tags): I/O memory in the CPU Unit can be externally accessed using symbols, depending on parameter settings. |
|||
| Data Type of Symbols | BOOL (bit)
UINT (one-word unsigned binary) UDINT (two-word unsigned binary) ULINT (four-word unsigned binary) INT (one-word signed binary) DINT (two-word signed binary) LINT (four-word signed binary) UINT BCD (one-word unsigned BCD) *5 UDINT BCD (two-word unsigned BCD) *5 ULINT BCD (four-word unsigned BCD) *5 REAL (two-word floating-point) LREAL (four-word floating-point) CHANNEL (word) NUMBER (constant or number) WORD (one-word hexadecimal) DWORD (two-word hexadecimal) LWORD (four-word hexadecimal) STRING (1 to 255 ASCII characters) TIMER (timer) *6 COUNTER (counter) *6 User-defined data types (data structures) |
||||
| Maximum Size of Symbol | 32k words | ||||
| Array Symbols (Array Variables) | One-dimensional arrays | ||||
| Number of Array Elements | 32,000 elements max. | ||||
| Number of Registrable Network
Symbols (Tags) |
10,000 max. | ||||
| Length of Network Symbol
(Tag) Name |
255 bytes max. | ||||
| Encoding of Network
Symbols (Tags) |
UTF-8 | ||||
| Data
Tracing |
Memory Capacity | 220,000 words | |||
| (Up to 32k words × the maximum bank number for the
CPU Unit when EM is specified in CX-Programmer) |
|||||
| Number of Samplings | Bits = 31, one-word data = 32, two-word data = 16,
four-word data = 8 |
||||
| Sampling Cycle | 1 to 2,550 ms (Unit: 1 ms) | ||||
| Trigger Conditions | • Bit
Upward/downward differentiation, ON, OFF AND/OR condition combinations for a maximum of 4 bits • Word =, >, ≥, <, ≤, ≠ AND/OR condition combinations for a maximum of 2 words • AND/OR condition combinations for bit conditions and word conditions |
||||
| File Memory | Memory Card HMC-SD[][][] is used
EM file memory (Part of the EM Area can be converted for use as file memory.) |
||||
| Source/Comment Memory | Program source,
comments, program index, and symbol table |
Capacity: 2 Mbytes | |||
| Commu-
nications |
Logical
Ports for Communications |
Logical Ports | 8 ports (Used for SEND, RECV, CMND, PMCR,
TXDU, and RXDU instructions.) |
||
| Extended
Logical Ports |
64 ports (Used for SEND2, RECV2, CMND2, and
PMCR2 instructions.) |
||||
| CIP
Communications Specification |
Class 3
(Number of Connections) |
Number of connections: 128 | |||
| UCMM (Non-
connection Type) |
Maximum number of clients that can communicate at
the same time: 32 Maximum number of servers that can communicate at the same time: 32 |
||||
| Peripheral (USB) Port | USB 2.0-compliant Type-C connector | ||||
| Baud Rate | 12 Mbps max. | ||||
| Serial Port | Interface: Conforms to EIA RS-232C. | ||||
| Communications Method | Half-duplex | ||||
| Synchronization Method | Start-stop | ||||
| Baud Rate | 0.3, 0.6, 1.2, 2.4, 4.8, 9.6, 19.2, 38.4, 57.6, or 115.2 (kbps) | ||||
| Transmission Distance | 15 m max. | ||||
| EtherNet/IP Port *7 | --- | ||||
| Trans-
mission Specifi- cations |
Media Access
Method |
CSMA/CD | |||
| Modulation | Baseband | ||||
| Transmission
Paths |
Star | ||||
| Baud Rate | 100 Mbps (100Base-TX) | ||||
| Transmission
Media |
Shielded twisted-pair (STP) cable; Categories: 5, 5e | ||||
| Transmission
Distance |
100 m (between Ethernet switch and node) | ||||
| Number of
Cascade Connections |
No restrictions if Ethernet switch is used. | ||||
| Commu-
nications Specifi- cations |
CIP
Communications: Tag Data Links |
--- | |||
| Number of
Connections |
256 | ||||
| Packet Interval
(Refresh period) |
0.5 to 10,000 ms (Unit: 0.5 ms)
Can be set for each connection. (Data will be refreshed at the set interval, regardless of the number of nodes.) |
||||
| Permissible
Communications Band *8 |
12,000 packets per second | ||||
| Number of
Registrable Tags |
256 | ||||
| Type of Tags | CIO, DM, EM, HR, WR, and network symbols | ||||
| Number of Tags
per Connection |
8 (Seven tags if PLC status is included in the segment.) | ||||
| Maximum Link
Data Size per Node |
184,832 words | ||||
| Maximum Data
Size per Connection |
252 or 722 words *9
(Data is synchronized within each connection.) |
||||
| Number of
Registrable Tag Set |
256 (1 connection = 1 segment) | ||||
| Maximum Tag
Set Size |
722 words (One word is used when PLC status is
included in the segment.) |
||||
| Maximum
Number of Tags Refreshable in a Single Cycle of CPU Unit *10 |
Output/send (CPU Unit to EtherNet/IP): 256
Input/receive (EtherNet/IP to CPU Unit): 256 |
||||
| Data Size
Refreshable in a Single Cycle of CPU Unit *10 |
Output/send (CPU to EtherNet/IP): 6,432 words
Input/receive (EtherNet/IP to CPU): 6,432 words |
||||
| Change of Tag
Data Link Parameter Settings during Operation |
Supported *11 | ||||
| Multi-cast
Packet Filter *12 |
Supported | ||||
| Quick Connect | Originator only is supported | ||||
| CIP
Communications: Explicit Messages |
--- | ||||
| Class 3
(Number of Connections) |
Number of connections: 128 | ||||
| UCMM (Non-
connection Type) |
Maximum number of clients that can communicate at
the same time: 32 Maximum number of servers that can communicate at the same time: 32 |
||||
| CIP Routing | Supported
(CIP routing is enabled for the following remote Units: CJ1W-EIP21/EIP21S, CJ3M-CPU3[], CJ2H-CPU6[]- EIP, CJ2M-CPU3[], and CS1W-EIP21/EIP21S.) |
||||
| FINS Communications | --- | ||||
| FINS/UDP | Supported | ||||
| FINS/TCP | 16 connections max. | ||||
| Socket Service (TCP) | 8 sockets max. | ||||
| Socket Service (UDP) | 8 sockets max. | ||||
| Modbus TCP Server | 8 connections max. | ||||
| Modbus UDP Server | Supported | ||||
| Modbus TCP Client | Possible by function block using Socket Service 8
connections max. |
||||
| Modbus UDP Client | Possible by function block using Socket Service 8
connections max. |
||||
| EtherNet/IP
Conformance Test |
Conforms to CT21. | ||||
| EtherNet/IP
Interface |
10Base-T/100Base-TX
Auto Negotiation/Fixed Setting |
||||
| Pulse I/O
(When using Pulse I/O Module) |
External interface | CJ2M-MD211 or CJ2M-MD212 Pulse I/O Module with
40-pin MIL connector |
|||
| Pulse Inputs | Can be used as normal inputs, interrupt inputs, quick-
response inputs, or high-speed counter inputs. (Functions of each input must be selected in the PLC Setup.) Input method: Line-driver input or 24-VDC input (selected by wiring) |
||||
| Normal inputs | 20 max. (10 per Pulse I/O Module)
Input constants: Set in the PLC Setup (0, 0.5, 1, 2, 4, 8, 16, or 32 ms). Default: 8 ms |
||||
| Interrupt inputs
and quick-response inputs |
8 max. (4 per Pulse I/O Module)
Input signal minimum ON pulse width: 30 μs |
||||
| High-speed counter inputs | 4 max. (2 per Pulse I/O Module)
Input method: Differential-phase (×4) pulses, pulse + direction, up/down pulses, or increment pulse Maximum response frequency: 50 kHz for differential phases or 100 kHz for single phase Counting mode: Linear mode or circular (ring) mode Count value: 32 bits Counter reset: Phase Z + software reset or software reset Control method: Target-value comparison or range comparison Gate function: Supported |
||||
| Pulse Outputs | Can be used as normal outputs, pulse outputs, or
PWM outputs. (Functions of each output must be selected in the PLC Setup.) Output method: Sinking or sourcing transistor outputs (The method is determined by Pulse I/O Module model.) |
||||
| Normal outputs | 12 max. (6 per Pulse I/O Module) | ||||
| Pulse outputs | 4 max. (2 per Pulse I/O Module)
Output method: CW/CCW or pulse + direction (The method is determined by the I/O wiring and the instructions used in the ladder program.) Output frequency: 1 pps to 100 kpps (in increments of 1 pps) Output Mode: Continuous mode (for speed control) or independent mode (for position control) Output pulses: Relative coordinates: 0000 0000 to 7FFF FFFF hex (0 to 2,147,483,647 pulses) Absolute coordinates: 8000 0000 to 7FFF FFFF hex (-2,147,483,648 to 2,147,483,647) Acceleration/deceleration curves: Linear or S-curve Origin search function: Supported |
||||
| PWM outputs | 4 max. (2 per Pulse I/O Module)
Output frequency: 0.1 to 6,553.5 Hz (in 0.1-Hz increments) or 1 to 32,800 Hz (in 1-Hz increments) Duty ratio: 0.0% to 100.0% (in 0.1% increments) |
||||
*1. The following times are added if EtherNet/IP data tag links are used.
CJ3M-CPU3[]: 100 μs + Number of transfer words × 0.78 μs
When the Pulse I/O Module is mounted, 10 μs × number of mounted units is added.
*2. A960 to A1471 and A10000 to A11535 cannot be accessed by CPU Bus Units, Special I/O Units, PTs, and Support Software that do not specifically support the CJ2/CJ3 CPU Units.
*3. Bits in the EM Area can be addressed either by bit or by word. These bits cannot be addressed by CPU Bus Units, Special I/O Units, PTs, and Support Software that do not specifically support the CJ3 CPU Units.
*4. Force-setting/resetting bits in the EM Area is possible either for banks that have been specified for automatic address allocation or for banks specified for the EM Area force-set/reset function.
*5. This data type cannot be used in Function blocks.
*6. This data type can be used only in Function blocks.
*7. The EtherNet/IP port is built into the CJ3M-CPU3[] only.
*8. “Packets per second” is the number of communications packets that can be processed per second.
*9. Large Forward Open (CIP optional specification) must be supported in order for 505 to 1,444 bytes to be used as the data size. Application is supported between CS/CJ-series PLCs. When connecting to devices from other manufacturers, make sure that the devices support the Large Forward Open specification.
*10. If the maximum number is exceeded, refreshing will require more than one CPU Unit cycle.
*11. When changing parameters, however, the EtherNet/IP port where the change is made will be restarted. In addition, a timeout will temporarily occur at the other node that was communicating with that port, and it will then recover automatically.
*12. The EtherNet/IP port supports an IGMP client, so unnecessary multicast packets are filtered by using an Ethernet switch that supports IGMP snooping.
Function Specifications
| Functions | Description | |||
|---|---|---|---|---|
| Cycle Time
Management |
Minimum Cycle Time | A minimum cycle time can be set.
(0.2 to 32,000 ms; Unit: 0.1 ms) The minimum cycle time setting can be changed in MONITOR mode |
||
| Cycle Time Monitoring | The cycle time is monitored.
(10 to 40,000 ms; Unit: 10 ms) |
|||
| Background Processing | Instructions with long execution times can be
executed over multiple cycles to prevent fluctuations in the cycle time. |
|||
| Unit (I/O)
Management |
Basic I/O
Units, Special I/O Units, and CPU Bus Units |
I/O
Refreshing |
Cyclic
Refreshing |
Cyclic refreshing of Basic I/O Units, Special I/O Units,
and CPU Bus Units |
| Immediate
Refreshing |
I/O refreshing by immediate refreshing instructions | |||
| Refreshing
by IORF |
I/O refreshing by IORF instruction | |||
| Unit Recognition at
Startup |
The number of units recognized when the power is
turned ON is displayed. |
|||
| Basic I/O
Units |
Input Response Time
Setting |
The input response times can be set for Basic I/O
Units. The response time can be increased to reduce the effects of chattering and noise at input contacts. The response time can be decreased to enable detecting shorter input pulses. |
||
| Load OFF Function | All of the outputs on Basic I/O Units can be turned
OFF when an error occurs in RUN or MONITOR mode. |
|||
| Basic I/O Unit Status
Monitoring |
Alarm information can be read from Basic I/O Units
and the number of Units recognized can be read. |
|||
| Special I/O
Units and CPU Bus Units |
Reading/writing data
using instructions for specific Units |
Special instructions can be used to read/write
required data for specific Units at high speed. |
||
| Unit Restart Bits to
Restart Units |
A Special I/O Unit or CPU Bus Unit can be
restarted. |
|||
| Configuration
Management |
Automatic I/O Allocation
at Startup |
I/O words can be automatically allocated to the
Basic I/O Units that are connected in the PLC to start operation automatically without registering Units into I/O tables. |
||
| I/O Table Creation | The current unit configuration can be registered in
I/O tables to prevent it from being changed, to reserve words, and to set words. |
|||
| Rack/Slot First Word
Settings |
The first words allocated to a Units on the Racks
can be set. |
|||
| Pulse I/O
Functions (When using Pulse I/O Module) |
Pulse Input
Functions |
Normal Inputs | Input signals are read during I/O refreshing and
stored in I/O memory. |
|
| Interrupt Inputs | An interrupt task can be started when an input
signal turns ON or turns OFF. |
|||
| Quick-response Inputs | Input signals that are shorter than the cycle time
are read and stored in I/O memory. |
|||
| High-speed Counter
Inputs |
High-speed pulse signals are counted. Interrupt
tasks can also be started. |
|||
| Pulse Output
Functions |
Normal Outputs | The status of I/O memory is output during I/O
refreshing. |
||
| Pulse Outputs | A pulse signal is output with the specified
frequency and number of pulses at a fixed duty ratio (50%). |
|||
| PWM Outputs | A pulse signal is output at the specified duty ratio. | |||
| Origin Searches | The origin point of the machine is determined
according to the specified origin search parameters while actually outputting pulses and using the origin and origin proximity input signals as conditions. (Pulse inputs and outputs are also used for this function.) |
|||
| Memory
Management |
Holding I/O Memory when
Changing Operating Modes |
The status of I/O memory can be held when the
operating mode is changed or power is turned ON. The forced-set/reset status can be held when the operating mode is changed or power is turned ON. |
||
| File Memory | Files (such as program files, data files, and
symbol table files) can be stored in Memory Card, EM File Memory, or Comment Memory. |
|||
| Built-in Flash Memory | The user program and Parameter Area can be
backed up to an internal flash memory when they are transferred to the CPU Unit. |
|||
| EM File Function | Parts of the EM Area can be treated as file memory. | |||
| Storing Comments | I/O comments can be stored as symbol table files
in a Memory Card, EM file memory, or comment memory. |
|||
| EM Configuration | EM Area can be set as trace memory or EM file memory. | |||
| Battery-free I/O Memory
Backup Function |
This function holds DM Area (D), EM Area (E),
Holding Area (H), Counter (C), and Auxiliary Area (A) data without the need for a battery when the power is interrupted. |
|||
| Memory Cards | Automatic File Transfer at Startup | A program file and parameter files can be read
from a Memory Card when the power is turned ON. |
||
| Program Replacement during
PLC Operation |
User programs can be transferred from a Memory
Card to CPU Unit during operation. |
|||
| Function for Reading and
Writing Data from a Memory Card |
Data in I/O memory in the CPU Unit can be written
to a Memory Card in CSV/TXT format. Data in CSV/TXT format in the Memory Card can be read to I/O memory in the CPU Unit. |
|||
| Communications | --- | |||
| Peripheral (USB) Port | Bus for communications with various kinds of
Support Software running on a personal computer. |
|||
| Serial Port | --- | |||
| Host Link (SYSWAY)
Communications |
Host Link commands or FINS commands placed
between Host Link headers and terminators can be sent from a host computer or PT to read/write I/O memory, read/control the operating mode, and perform other operations for PLC. |
|||
| No-protocol
Communications |
I/O instructions for communications ports (such
as TXD/RXD instructions) can be used for data transfer with peripheral devices such as bar code readers and printers. |
|||
| NT Link
Communications |
I/O memory in the PLC can be allocated and
directly linked to various PT functions, including status control areas, status notification areas, touch switches, lamps, memory tables, and other objects. |
|||
| Peripheral Bus | Bus for communications with various kinds of
Support Software running on a personal computer. |
|||
| Serial Gateway | This gateway enables receiving and automatically converting FINS to the CompoWay/F. | |||
| Serial PLC Links | Data is exchanged between CPU Units using
serial ports without communications programming. PTs set to the 1:N NT Link protocol can be included in the network. |
|||
| EtherNet/IP Port *1 | 100Base-TX/10Base-T
Protocols: TCP/IP, UDP, ARP, ICMP (ping only), BOOTP, LLDP Applications: FINS, CIP, SNTP, DNS (Client), FTP (Server), Modbus (Server) |
|||
| CIP
Commu- nications Service |
Tag Data
Links |
Programless cyclic data exchanges with the
devices on the EtherNet/IP network. |
||
| Message
Commu- nications |
Any CIP commands can be received from the
devices on the EtherNet/IP network. |
|||
| FINS
Commu- nications Service |
Message
Commu- nications |
Any FINS commands can be transferred with the
devices on the EtherNet/IP network. |
||
| Socket
service |
Message
Commu- nications |
Any data can be sent and received to and from
general-purpose devices over Ethernet. |
||
| Modbus
Commu- nications Service |
Message
Commu- nications |
Modbus commands can be sent and received to
and from Modbus clients and Modbus servers on an EtherNet/IP network. |
||
| Interrupt | Scheduled Interrupts | A task is executed at a specified interval. | ||
| Resetting and
restarting with MSKS |
When MSKS is executed, the internal timer is
restarted and the time to first interrupt is set to a fixed value. |
|||
| Reading present value
of internal timer with MSKR |
MSKR can be used to read the time that has
elapsed until the scheduled interrupt is started or since the previous scheduled interrupt. |
|||
| Power OFF Interrupts | A task can be executed when CPU Unit's power
turns OFF. |
|||
| I/O Interrupts | A task can be executed when an input signal is
input to an Interrupt Input Unit. |
|||
| External Interrupts | A task can be executed when interrupts are
requested from a Special I/O Unit or a CPU Bus Unit. |
|||
| Input Interrupt Function of Pulse
I/O Module |
A task is started for an interrupt input from a Pulse
I/O Module or for a high-speed counter input. |
|||
| Input Interrupts | Interrupt tasks are executed when the interrupt
input turns ON or turns OFF. Direct Mode: An interrupt task is executed each time an input signal changes. Counter Mode: Changes in the input signal are counted up or down and the interrupt task is executed when the counter counts out. (The maximum response frequency is 3 kHz.) |
|||
| High-speed Counter
Interrupts |
An interrupt task is executed when preset
comparison conditions for a high-speed counter are met. Target-value comparison: The interrupt task is executed when the count matches a specified value. Range comparison: The interrupt task is executed when the count enters or leaves a specified range of values. |
|||
| Clock | Clock Function | Clock data is stored in memory.
Accuracy (Accuracy depends on the temperature.) Ambient temperature of 55°C: -3.5 to 0.5 min error per month Ambient temperature of 25°C: -1.5 to 1.5 min error per month Ambient temperature of 0°C: -3 to 1 min error per month |
||
| Built-in Capacitor Backup Time | At ambient temperature of 40°C: 10 days | |||
| Operation Start Time Storage | The time when operating mode was last changed
to RUN mode or MONITOR mode is stored. |
|||
| Operation Stop Time Storage | The last time a fatal error occurred or the last time
the operating mode was changed to PROGRAM mode is stored. |
|||
| Startup Time Storage | The time when the power was turned ON is stored. | |||
| Power Interruption Time Storage | The time when the power is turned OFF is stored. | |||
| Total Power ON Time Calculation | The total time that the PLC has been ON is stored
in increments of 10 hours. |
|||
| Power ON Clock Data Storage | A history of the times when the power was turned
ON is stored. |
|||
| User Program Overwritten Time
Storage |
The time that the user program was last overwritten
is stored. |
|||
| Parameter Date Storage | The time when the Parameter Area was overwritten
is stored. |
|||
| Power Supply Management | Memory Protection | Holding Area data, DM Area data, EM Area data,
Counter Completion Flags, and counter present values are held even when power is turned OFF. CIO Area, Work Area, some Auxiliary Area data, and Timer Completion Flags, timer present values, index registers, and data registers can be protected by turning ON the IOM Hold Bit in the Auxiliary Area, and by also setting the IOM Hold Bit to “Hold” in the PLC Setup. |
||
| Power OFF Detection Time Setting | The detection time for power interruptions can be
set. AC power supply: 10 to 25 ms (variable) DC power supply: 2 to 5 ms (CJ1W-PD022) or 2 to 20 ms (CJ1W-PD025) |
|||
| Power OFF Detection Delay Time | The detection of power interruptions can be
delayed: 0 to 10 ms (Not supported by the CJ1W-PD022.) |
|||
| Number of Power Interruptions
Counter |
The number of times power has been interrupted
is counted. |
|||
| Function Blocks | Standard programming can be encapsulated as
function blocks. |
|||
| Languages in Function Block
Definitions |
Ladder programming or structured text | |||
| Debugging | Online Editing | The program can be changed during operation
(in MONITOR or PROGRAM mode), except for block programming areas. |
||
| Force-Set/Reset | Specified bits can be set or reset.
A parameter can be set to enable force-setting/ resetting bits in EM Area banks. Force-setting/resetting is enabled for the specified bank and all the banks after it. |
|||
| Differentiate Monitoring | ON/OFF changes in specified bits can be monitored. | |||
| Data Tracing | The specified I/O memory data can be stored in the
trace memory in the CPU Unit. The triggers can be set. |
|||
| Continuous Tracing | The trace data can be uploaded during data tracing
using the CX-Programmer. This enables continuously logging the data by constantly uploading the trace data. |
|||
| Automatically starting
tracing when operation starts |
Data tracing can be automatically started when
operation is started (i.e., when the operating mode is changed from PROGRAM mode to MONITOR or RUN mode). |
|||
| Storing Location of Error when an
Error Occurs |
The location and task number where execution
stopped for a program error is recorded. |
|||
| Program Check | The programs can be checked for items such as no
END instruction and FALS/FAL errors at startup. |
|||
| Self-
diagnosis and Restoration |
Error Log | A function is provided to store predefined error
codes in CPU Unit, error information, and time at which the error occurred. |
||
| CPU Error Detection | CPU Unit WDT errors are detected. | |||
| User-defined Failure Diagnosis | Errors can be generated for user-specified
conditions: Non-fatal errors (FAL) and fatal errors (FALS). Program section time diagnosis and program section logic diagnosis are supported (FPD instruction). |
|||
| Load OFF Function | This function turns OFF all outputs from Output
Units when an error occurs. |
|||
| RUN Output | The RUN output from the CJ1W-PA205R turns ON
while CPU Unit is in RUN mode or MONITOR mode. |
|||
| Basic I/O Load Short-circuit Detection | This function provides alarm information from Basic
I/O Units that have load short-circuit protection. |
|||
| Failure Point Detection | The time and logic of an instruction block can be
analyzes using the FPD instruction. |
|||
| CPU Standby Detection | This function indicates when the CPU Unit is on
standby because all Special I/O Units and CPU Bus Units have not been recognized at the startup in RUN or MONITOR mode. |
|||
| Non-fatal Error
Detection |
System FAL Error
Detection (User- defined non-fatal error) |
This function generates a non-fatal (FAL) error when
the user-defined conditions are met in program. |
||
| Duplicated Refreshing
Error Detection |
This function detects an error when an immediate
refreshing Instruction in an interrupt task is competing with I/O refreshing of a cyclic task. |
|||
| Basic I/O Unit Error
Detection |
This function detects the errors in Basic I/O Units. | |||
| Backup Memory
Error Detection |
This function detects errors in the memory backup
of the user programs and parameter area (backup memory). |
|||
| PLC Setup Error Detection | This function detects setting errors in the PLC Setup. | |||
| CPU Bus Unit Error
Detection |
This function detects an error when there is an error
in data exchange between the CPU Unit and a CPU Bus Unit. |
|||
| Special I/O Unit Error
Detection |
This function detects an error when there is an error
in data exchange between the CPU Unit and a Special I/O Unit. |
|||
| Tag Memory Error
Detection |
This function detects errors in tag memory. | |||
| Battery Error Detection | This function detects an error when a battery is not
connected to the CPU Unit or when the battery voltage drops. |
|||
| CPU Bus Unit Setting
Error Detection |
This function detects an error when the model of a
CPU Bus Unit in the registered I/O tables does not agree with the model that is actually mounted in the PLC. |
|||
| Special I/O Unit Setting
Error Detection |
This function detects an error when the model of a
Special I/O Unit in the registered I/O tables does not agree with the model of Unit that is actually mounted. |
|||
| Fatal
Error Detection |
Memory Error Detection | This function detects errors that occur in memory of
the CPU Unit. |
||
| I/O Bus Error Detection | This function detects when an error occurs in data
transfers between the Units mounted in Rack slots and the CPU Unit and detects when the End Cover is not connected to the CPU Rack or an Expansion Rack. |
|||
| Unit/Rack Number
Duplication Error |
This function detects an error when the same unit
number is set for two or more Units, the same word is allocated to two or more Basic I/O Units, or the same rack number is set for two or more Racks. |
|||
| Too Many I/O Points
Error Detection |
This function detects an error when the total number
of I/O points set in the I/O tables or the number of Units per Rack exceeds the specified range. |
|||
| I/O Setting Error
Detection |
The registered I/O tables are used to detect errors
if the number of Units in the registered I/O tables does not agree with the actual number of Units that are connected or an Interrupt Unit has been connected in the wrong position. |
|||
| Program Error Detection | This function detects errors in programs. | |||
| Instruction
Processing Error Detection |
This function detects an error when the given data value is invalid when executing an instruction, or execution of instruction between tasks was attempted. | |||
| Indirect
DM/EM BCD Error Detection |
This function detects an error when an indirect
DM/EM address in BCD mode is not BCD. |
|||
| Illegal Area
Access Error Detection |
This function detects an error when an attempt is
made to access an illegal area with an instruction operand. |
|||
| No END
Error Detection |
This function detects an error when there is no END
instruction at the end of the program. |
|||
| Task Error
Detection |
This function detects an error when there are no
tasks that can be executed in a cycle, there is no program for a task, or the execution condition for an interrupt task was met but there is no interrupt task with the specified number. |
|||
| Differen-
tiation Overflow Error Detection |
This function detects an error when too many
differentiated instructions are entered or deleted during online editing (131,072 times or more). |
|||
| Invalid
Instruction Error Detection |
This function detects an error when an attempt is
made to execute an instruction that is not defined in the system. |
|||
| User
Program Area Overflow Error Detection |
This function detects an error when instruction data
is stored after the last address in user program area. |
|||
| Cycle Time Exceeded
Error Detection |
This function monitors the cycle time (10 to
40,000 ms) and stops the operation when the set value is exceeded. |
|||
| System FALS Error
Detection (User- defined Fatal Error) |
This function generates a fatal (FALS) error when
the user-defined conditions are met in program. |
|||
| Version Error Detection | This function detects an error when a user program
includes a function that is not supported by the current unit version. |
|||
| Memory Card Transfer
Error Detection |
This function detects an error when the automatic
file transfer from Memory Card fails at startup. |
|||
| Maintenance | Simple Backup Function | This function collectively backs up the data in CPU
Unit (user programs, parameters, and I/O memory) and internal backup data in the I/O Units. |
||
| Unsolicited Communications | A function that allows the PLC to use Network
Communications Instruction to send required FINS commands to a computer connected via a Host Link |
|||
| Remote Programming and Monitoring | Host Link communications can be used for remote
programming and remote monitoring through a Controller Link, Ethernet, DeviceNet, or SYSMAC LINK Network. Communications across network layers can be performed. Controller Link or Ethernet: 8 layers DeviceNet or SYSMAC LINK: 3 layers |
|||
| Automatic Online
Connection via Network |
Direct
Connection |
This function enables automatically connecting to
the PLC online when the CX-Programmer is directly connected by a serial connection (peripheral (USB) port or serial port). |
||
| Via
Networks |
This function enables connecting the
CX-Programmer online to a PLC that is connected via an EtherNet/IP network. |
|||
| Security | Read Protection using Password | This function protects reading and displaying programs and tasks using passwords.
Write protection: Set using the DIP switch. Read protection: Set a password using the CX-Programmer. |
||
| FINS Write Protection | This function prohibits writing by using FINS
commands sent over the network. |
|||
| Unit Name Function | This function allows the users to give any names to
the Units. Names are verified at online connection to prevent wrong connection |
|||
| Hardware ID Using Lot Numbers | This function sets operation protection by identifying
hardware using the user programs according to lot numbers stored in the Auxiliary Area. |
|||
| Operation Log Function | Function for recording important operations and the
results of operations performed by online users while they are online together with the date, IP address of PC, and user name. |
|||
| Extended FINS Write Access Log | Function for retaining a log of requests to write to
the CPU Unit from external sources when the source address is not the local node. |
|||
| File Encryption Function | Function for encrypting files handled by
CX-Programmer, backup tools, and file memory to prevent unauthorized access by third parties. |
|||
| Secure Communications Function *2 | Function for ensuring the confidentiality and integrity
of the line used to access important data on the CPU Unit from peripheral tools. |
|||
| User authentication *2 | Function for allowing only specified users to perform
online operation from peripheral tools to further restrict online operation based on privileges set for each user. |
|||
| Port Open/Close Function *2 | Function for allowing you to block or allow
communications to pass through the TCP/ UDP ports allocated to individual communication functions according to the configured setting. |
|||
| IP Packet Filter *2 | Function for selectively allowing packets received by
the EtherNet/IP port to pass through based on preset conditions. |
|||
*1. Supported only by CJ3M-CPU[].
*2. This function can be used only with CJ3M-CPU3[].
Specifications for Pulse I/O Functions
The following functions of CJ3M can be used by installing one or two Pulse I/O Modules. Each module has 10 high-speed inputs and 6 high-speed outputs.
• The inputs can be used as general-purpose inputs, interrupt inputs, quick-response inputs, high-speed counters, or origin search inputs.
• The outputs can be used as general-purpose outputs, pulse outputs, origin search outputs, or PWM outputs.
One Pulse I/O Module can be mounted
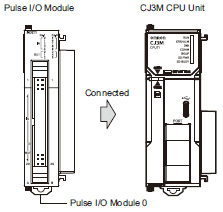
Two Pulse I/O Modules can be mounted
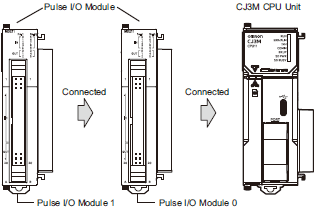
Note: The Pulse I/O Module closest to the CPU Unit is Pulse I/O Module 0 and the other one is Pulse I/O Module 1.
Performance Specifications
| Item | Description | ||
|---|---|---|---|
| Pulse I/O | Model of Pulse I/O Modules | CJ2M-MD211 (Sinking-type)
CJ2M-MD212 (Sourcing-type) |
|
| External Interface | 40-pin MIL connector | ||
| Pulse Inputs | Can be used as normal inputs, interrupt inputs, quick-response inputs,
or high-speed counter inputs. (Function of each input must be selected in the PLC Setup.) Input method: Line-driver input or 24-VDC input (selected by wiring) |
||
| Normal Inputs | 20 max. (10 per Pulse I/O Module)
Input constants: Set in the PLC Setup (0, 0.5, 1, 2, 4, 8, 16, or 32 ms). Default: 8 ms |
||
| Interrupt Inputs and
Quick-response Inputs |
8 max. (4 per Pulse I/O Module)
Input signal minimum ON pulse width: 30 μs |
||
| High-speed Counter Inputs | 4 max. (2 per Pulse I/O Module)
Input method: Differential-phase (×4) pulses, pulse + direction, up/down pulses, or increment pulse Maximum response frequency: 50 kHz for differential phases or 100 kHz for single phase Counting mode: Linear mode or circular (ring) mode Count value: 32 bits Counter reset: Phase Z + software reset or software reset Control method: Target-value comparison or range comparison Gate function: Supported |
||
| Pulse Outputs | Can be used as normal outputs, pulse outputs, or PWM outputs.
(Function of each output must be selected in the PLC Setup.) Output method: Sinking or sourcing transistor outputs (The method is determined by Pulse I/O Module model.) |
||
| Normal Outputs | 12 max. (6 per Pulse I/O Module) | ||
| Pulse Outputs | 4 max. (2 per Pulse I/O Module)
Output method: CW/CCW or pulse + direction (The method is determined by the I/O wiring and the instructions used in the ladder program.) Output frequency: 1 pps to 100 kpps (in increments of 1 pps) Output Mode: Continuous mode (for speed control) or independent mode (for position control) Output pulses: Relative coordinates: 0000 0000 to 7FFF FFFF hex (0 to 2,147,483,647 pulses) Absolute coordinates: 8000 0000 to 7FFF FFFF hex (-2,147,483,648 to 2,147,483,647) Acceleration/deceleration curves: Linear or S-curve Origin search function: Supported |
||
| PWM Outputs | 4 max. (2 per Pulse I/O Module)
Output frequency: 0.1 to 6,553.5 Hz (in 0.1-Hz increments) or 1 to 32,800 Hz (in 1-Hz increments) Duty ratio: 0.0% to 100.0% (in 0.1% increments) |
||
Function Specifications
| Functions | Description | |||
|---|---|---|---|---|
| Pulse I/O
Functions |
Pulse Input
Functions |
Normal Inputs | Input signals are read during I/O refreshing and stored in I/O memory. | |
| Interrupt Inputs | An interrupt task can be started when an input signal turns ON or
turns OFF. |
|||
| Quick-
response Inputs |
Input signals that are shorter than the cycle time are read and stored
in I/O memory. |
|||
| High-speed
Counter Inputs |
High-speed pulse signals are counted. Interrupt tasks can also be
started. |
|||
| Pulse Output
Functions |
Normal Outputs | The status of I/O memory is output during I/O refreshing. | ||
| Pulse Outputs | A pulse signal is output with the specified frequency and number of
pulses at a fixed duty ratio (50%). |
|||
| PWM Outputs | A pulse signal is output at the specified duty ratio. | |||
| Origin Searches | The origin point of the machine is determined according to the
specified origin search parameters while actually outputting pulses and using the origin and origin proximity input signals as conditions. (Pulse inputs and outputs are also used for this function.) |
|||
| Interrupt | Input Interrupt Function | A task is started for an interrupt input from a Pulse I/O Module or for a
high-speed counter input. |
||
| Input Interrupts | Interrupt tasks are executed when the interrupt input turns ON or turns
OFF. Direct Mode: An interrupt task is executed each time an input signal changes. Counter Mode: Changes in the input signal are counted up or down and the interrupt task is executed when the counter counts out. (The maximum response frequency is 3 kHz.) |
|||
| High-speed Counter
Interrupts |
An interrupt task is executed when preset comparison conditions for
a high-speed counter are met. Target-value comparison: The interrupt task is executed when the count matches a specified value. Range comparison: The interrupt task is executed when the count enters or leaves a specified range of values. |
|||
Specifications of Pulse Input Functions
Interrupt Inputs
| Item | Direct Mode | Counter Mode |
|---|---|---|
| Number of interrupt inputs | Max. 8 inputs | |
| Allocated bit | CIO 2960 and CIO 2962, bits 00 to 03 | |
| Interrupt detection method | ON-to-OFF or OFF-to-ON transitions | |
| Interrupt task numbers | 140 to 147 (fixed) | |
| Counting method | --- | Incrimenting or decrementing
(Set with the MSKS(690) instruction.) |
| Counting range | --- | 0001 to FFFF hex (16 bits)
(Set in A532 to A535 and A544 to A547.) |
| Response frequency | --- | Single-phase: 3 kHz × 8 inputs |
| Storage locations for PVs for
interrupt inputs in Counter Mode |
--- | A536 to A539 and A548 to A551 |
Quick-response inputs
| Item | Specifications |
|---|---|
| Number of Quick-response inputs | Max. 8 inputs |
| Quick-response inputs | Signals that are shorter than the cycle time are latched for one PLC cycle,
so they can be detected in the PLC program. Minimum detectable pulse width is 30 μs. |
High-speed Counter Inputs
| Item | Description | ||||
|---|---|---|---|---|---|
| Number of High-speed
Counter Inputs |
Max. 4 inputs | ||||
| Pulse input method
(counting mode) |
Incremental pulse
inputs |
Differential phase
input (4×) |
Up/down inputs | Pulse + direction
inputs |
|
| Input signals | Increment pulse | Phase A | Up pulse | Pulse | |
| --- | Phase B | Down pulse | Direction | ||
| --- | Phase Z | Reset | Reset | ||
| Frequency and number
of high-speed counters |
100 kHz, 2 inputs
× 2 I/O Modules |
50 kHz, 2 inputs
× 2 I/O Modules |
100 kHz, 2 inputs
× 2 I/O Modules |
100 kHz, 2 inputs
× 2 I/O Modules |
|
| Counting mode | Linear mode or ring mode | ||||
| Count value | Linear mode: 8000 0000 to 7FFF FFFF hex
0000 0000 to FFFF FFFF hex (for increment pulse) Ring mode: 0000 0000 to Max. ring value |
||||
| High-speed counter PV
storage locations |
High-speed counter 0: A271 (upper 4 digits) and A270 (lower 4 digits)
High-speed counter 1: A273 (upper 4 digits) and A272 (lower 4 digits) High-speed counter 2: A317 (upper 4 digits) and A316 (lower 4 digits) High-speed counter 3: A319 (upper 4 digits) and A318 (lower 4 digits) Refreshed during overseeing processing. Use PRV(881) to read the most recent PVs. |
||||
| Data format: 8 digit hexadecimal
• Linear mode: 8000 0000 to 7FFF FFFF hex 0000 0000 to FFFF FFFF hex (for increment pulse) • Ring mode: 0000 0000 to Max. ring value |
|||||
| Control
method |
Target value
comparison |
Up to 48 target values and corresponding interrupt task numbers can be registered. | |||
| Range
Comparison |
Up to 8 or up to 32 ranges can be registered, with a separate upper limit, lower limit,
and interrupt task number for each range. |
||||
| Counter reset method | • Phase-Z + Software reset
The counter is reset when the phase-Z input goes ON while the Reset Bit (A531.00 to A531.03) is ON. • Software reset The counter is reset when the Reset Bit (A531.00 to A531.03) is turned ON. Operation can be set to stop or continue the comparison operation when the high-speed counter is reset. |
||||
Specifications of Pulse Output Functions
Position Control and Speed Control
| Item | Specifications |
|---|---|
| Number of Pulse Outputs | Max. 4 outputs (Pulse Output 00 to 03) |
| Output mode | Continuous mode (for speed control) or independent mode (for position control) |
| Positioning
(independent mode) instructions |
PULS (886) and SPED (885), PULS (886) and ACC (888), or PULS2
(887) instruction |
| Speed control
(continuous mode) instructions |
SPED (885) and ACC (888) instructions |
| Origin (origin search
and origin return) instructions |
ORG (889) instruction |
| Interrupt feeding instruction | IFEED (892) instruction |
| Output frequency | 1 pps to 100 kpps (1 pps units), two pulse outputs × 2 Pulse I/O Modules |
| Frequency acceleration
and deceleration rates |
Set in increments of 1 pps for acceleration/deceleration rates from 1 to 65,535
pps (every 4 ms). The acceleration and deceleration rates can be set independently only with the PLS2 (887) instruction. |
| Changing SVs during
instruction execution |
The target frequency, acceleration/deceleration rate, and target position can be
changed. |
| Pulse output method | CW/CCW or pulse + direction |
| Number of output pulses | Relative coordinates: 0000 0000 to 7FFF FFFF hex (Accelerating or decelerating
in either direction: 2,147,483,647) Absolute coordinates: 8000 0000 to 7FFF FFFF hex (-2,147,483,648 to 2,147,483,647) |
| Relative/absolute
coordinate specifications for pulse output PVs |
Absolute coordinates are specified automatically when the origin location has
been defined by changing the pulse output PV with the INI (880) instruction or performing an origin search with the ORG(889) instruction. Relative coordinates must be used when the origin is undefined. |
| Relative pulse/absolute
pulse specifications |
The pulse type can be specified with an operand in the PULS (886) or PLS2
(887) instruction. Absolute pulses can be used when absolute coordinates are specified for the pulse output PV, i.e. the origin location has been defined. Absolute pulse cannot be used when relative coordinates are specified, i.e., when the origin location is undefined. An instruction error will occur. |
| Pulse output PV's storage
location |
The following Auxiliary Area words contain the pulse output PVs
Pulse output 0: A277 (leftmost 4 digits) and A276 (rightmost 4 digits) Pulse output 1: A279 (leftmost 4 digits) and A278 (rightmost 4 digits) Pulse output 2: A323 (leftmost 4 digits) and A322 (rightmost 4 digits) Pulse output 3: A325 (leftmost 4 digits) and A324 (rightmost 4 digits) The PVs are refreshed during regular I/O refreshing. |
Variable-duty Pulse Outputs (PWM)
| Item | Specifications |
|---|---|
| Number of PWM Outputs | Max. 4 outputs (PWM Output 00 to 03) |
| Duty ratio | 0.0% to 100.0% in 0.1% increments |
| Frequency | 0.1 Hz to 6,553.5 Hz (Set in 0.1-Hz increments.)
1 Hz to 32,800 Hz (Set in 1-Hz increments.) |
| Output mode | Continuous Mode |
| Instruction | PWM (891) instruction |
last update: October 1, 2026
 Top of page